ME4: Exoskeleton-Controlled Humanoid Robot
Exoskeleton-controlled humanoid robot
Project Overview
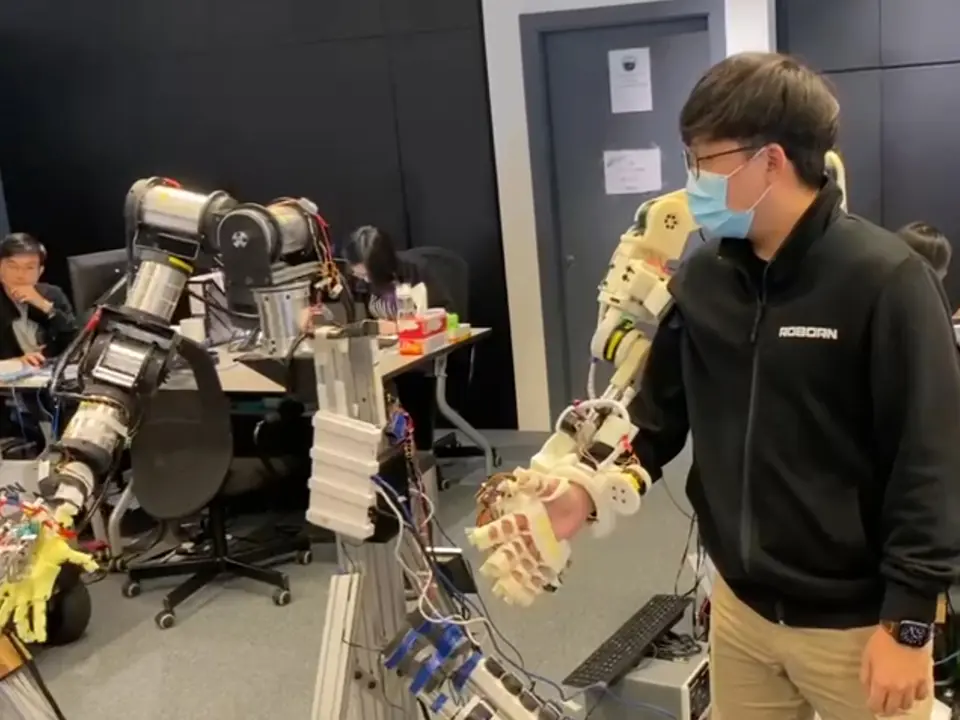
ME4 combines a humanoid robot with a wearable exoskeleton controller. The controller provides an interface for operating the robot, supported by haptic feedback, wireless communication, and motor-control software.
Project Details
Selected Contributions
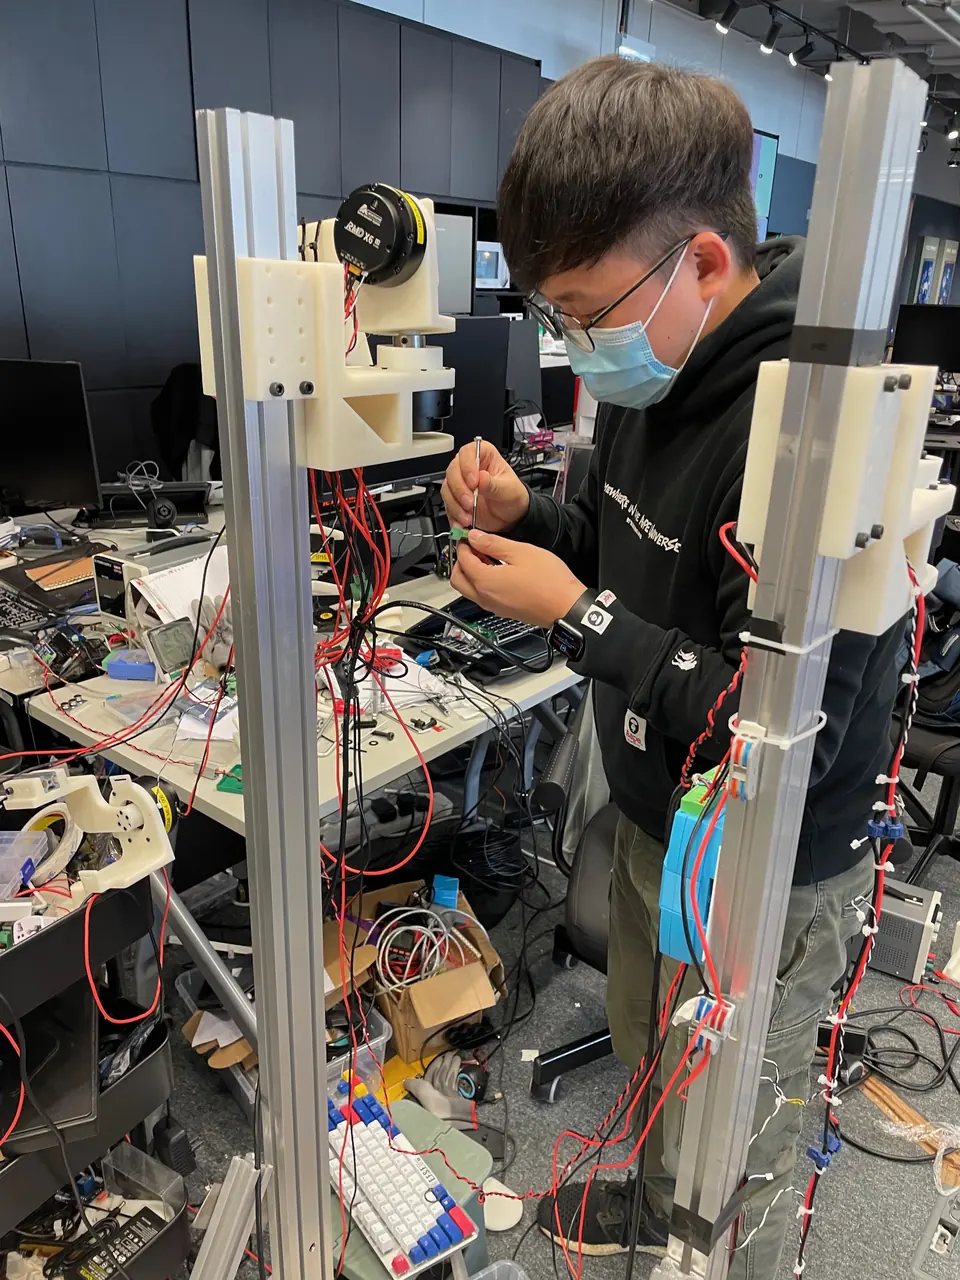
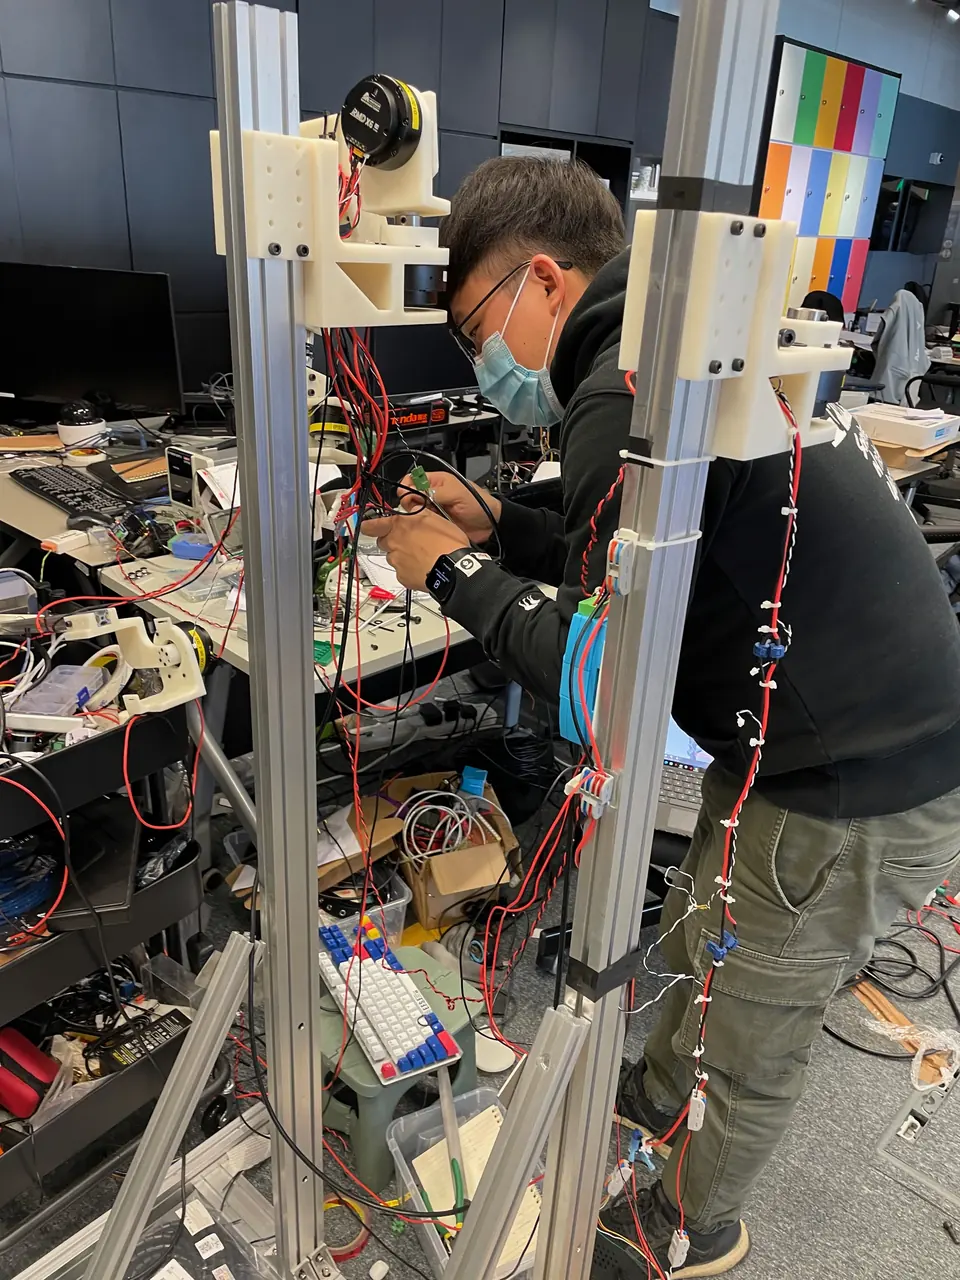
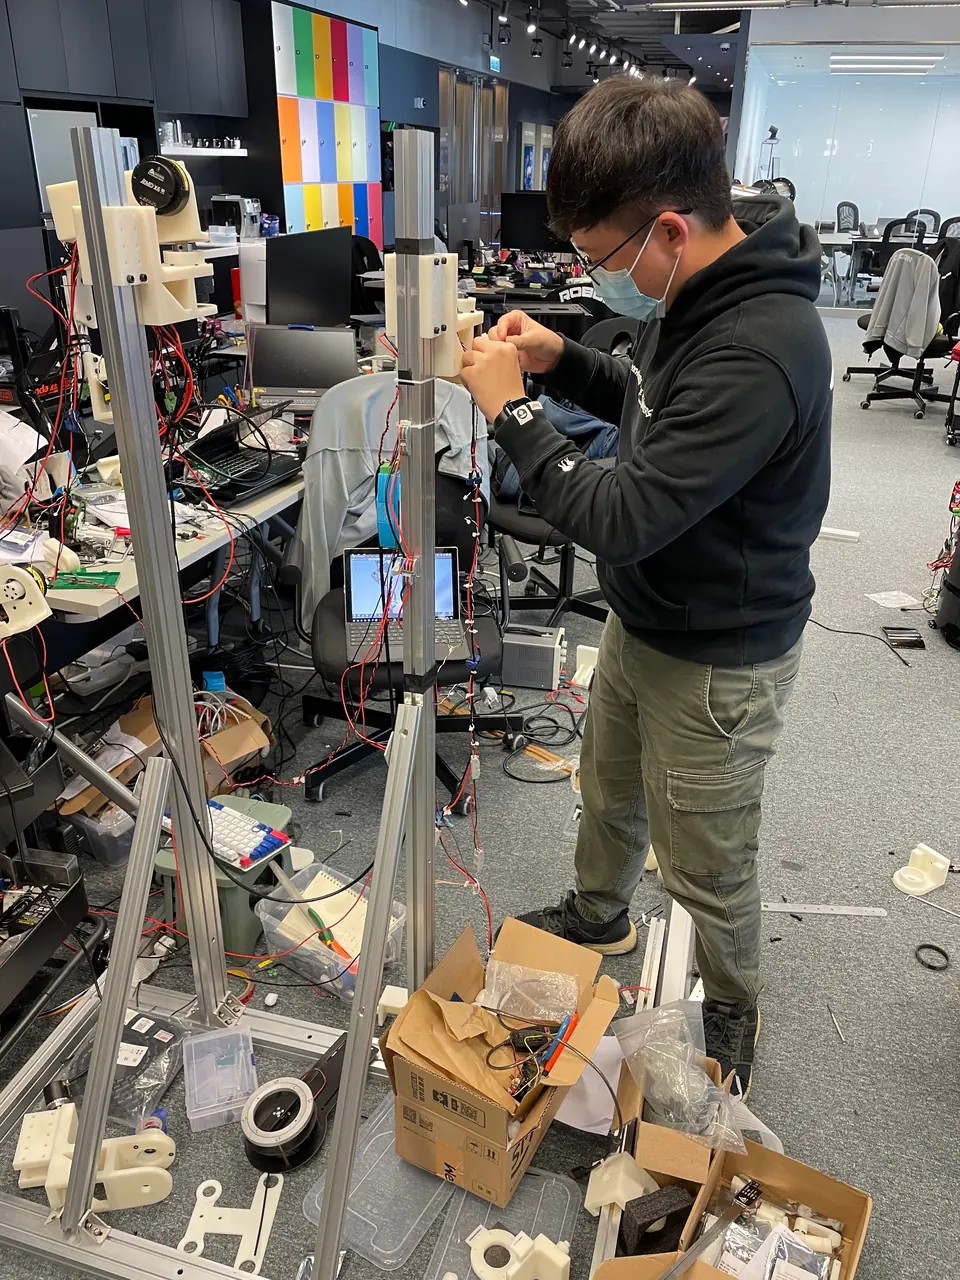
- Designed the mechanical structure and electrical layout for both the wearable controller and humanoid robot.
- Implemented haptic feedback and tuned the mechanism to reduce vibration.
- Developed Linux software for 48 V high-torque BLDC control and wireless communication.
- Maintained the robotic platform, including repairs to 5G communication transmitters and LiDAR modules.