SuperLimb Wireless Motorized Foot Controller
Hands-free robot control
Project Overview
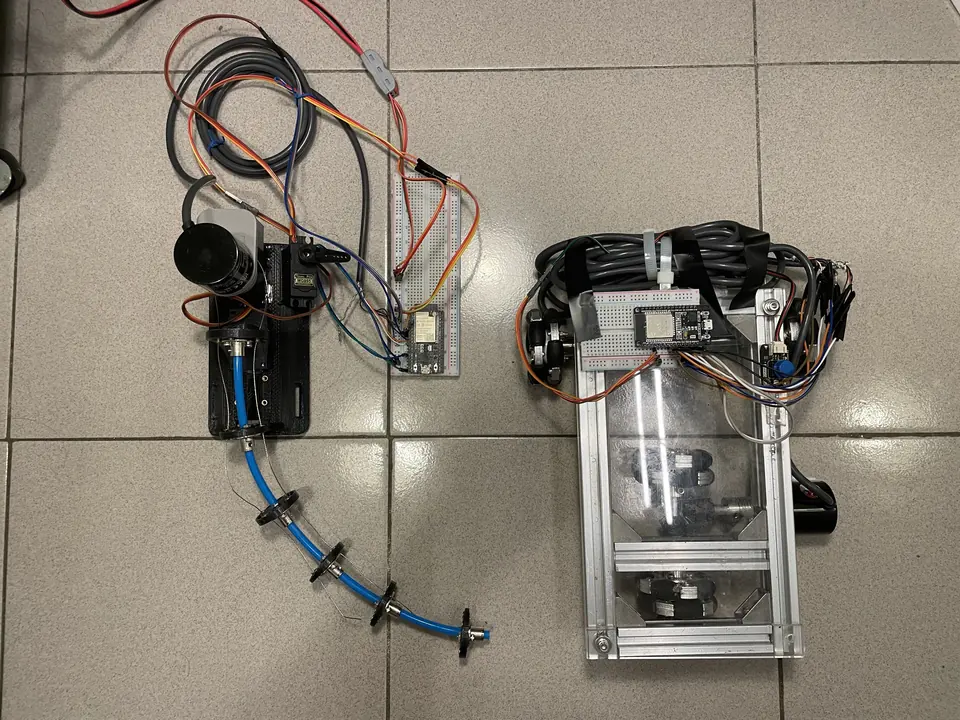
This wireless motorized foot controller was developed for the SuperLimb project. It uses foot input to command robotic motion, allowing the operator's hands to remain available for other tasks.
Project Details
The prototype combines mechanical design, embedded electronics, haptic feedback, and wireless communication in a wearable human-robot control interface.
Selected Contributions
- Designed the mechanical layout and wearable form of the motorized foot interface.
- Integrated embedded electronics, wireless communication, and haptic feedback for robot control.
- Developed the control approach around precise, ergonomic multi-axis input for SuperLimb.