Autonomous Wall Spraying Robot
Mobile wall-spraying robot
Project Overview
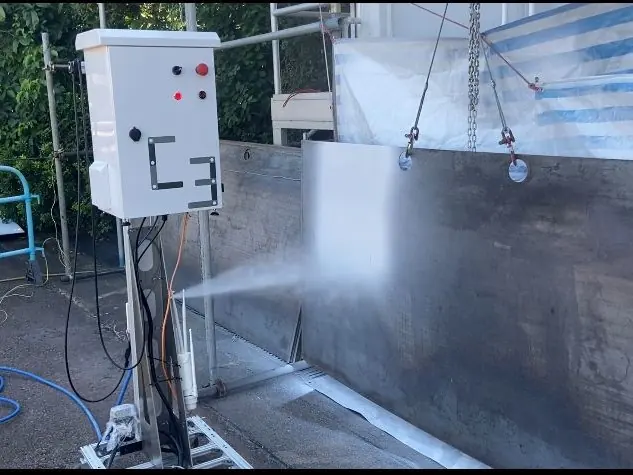
This mobile robot prototype was developed to automate wall spraying. Its ROS-based control system coordinates the mobile platform, linear rail, and motorized sprayer, with cameras and inertial sensing to support positioning.
Project Details
Selected Contributions
- Guided a master's student project from early concept through integrated robot development.
- Improved the mechanical architecture with a four-bar linkage and structural design reviews.
- Integrated AGV motion, IMU sensing, linear positioning, and the motorized sprayer through ROS.
- Developed a follow-on opportunity with Towngas Hong Kong for production-plant tank spraying.