CU-Brick: Cable-Driven Bricklaying Robot
Cable-driven bricklaying robot
Project Overview
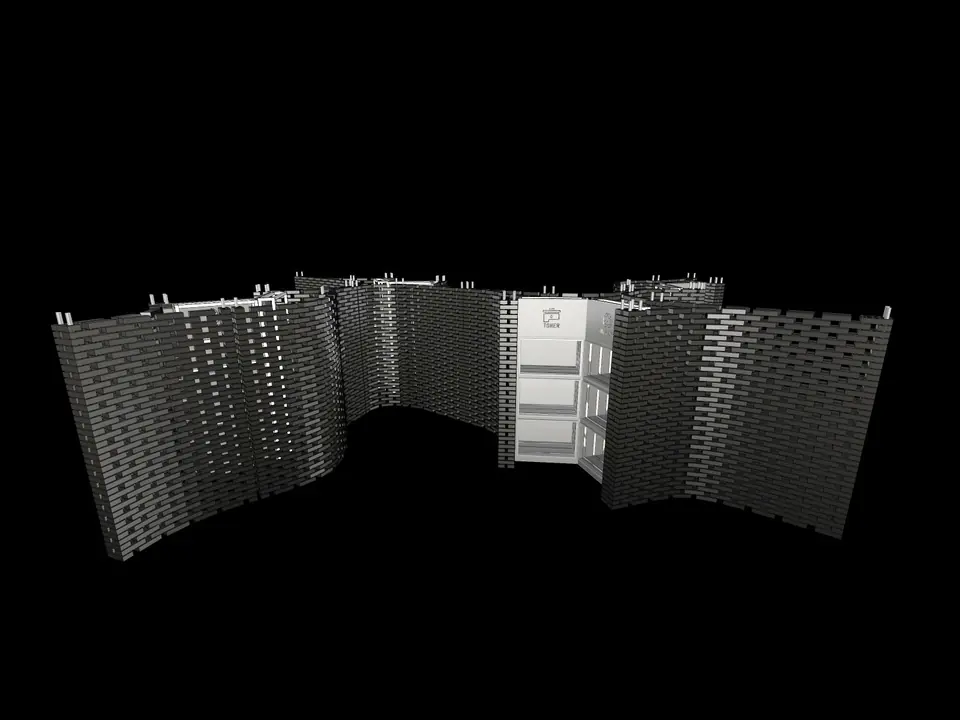
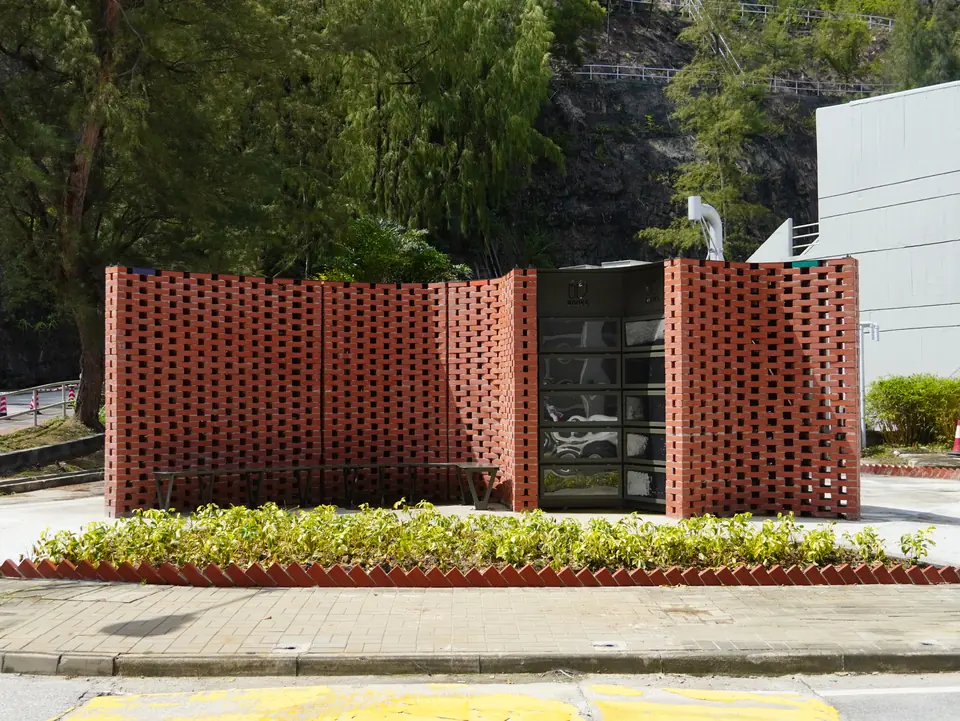
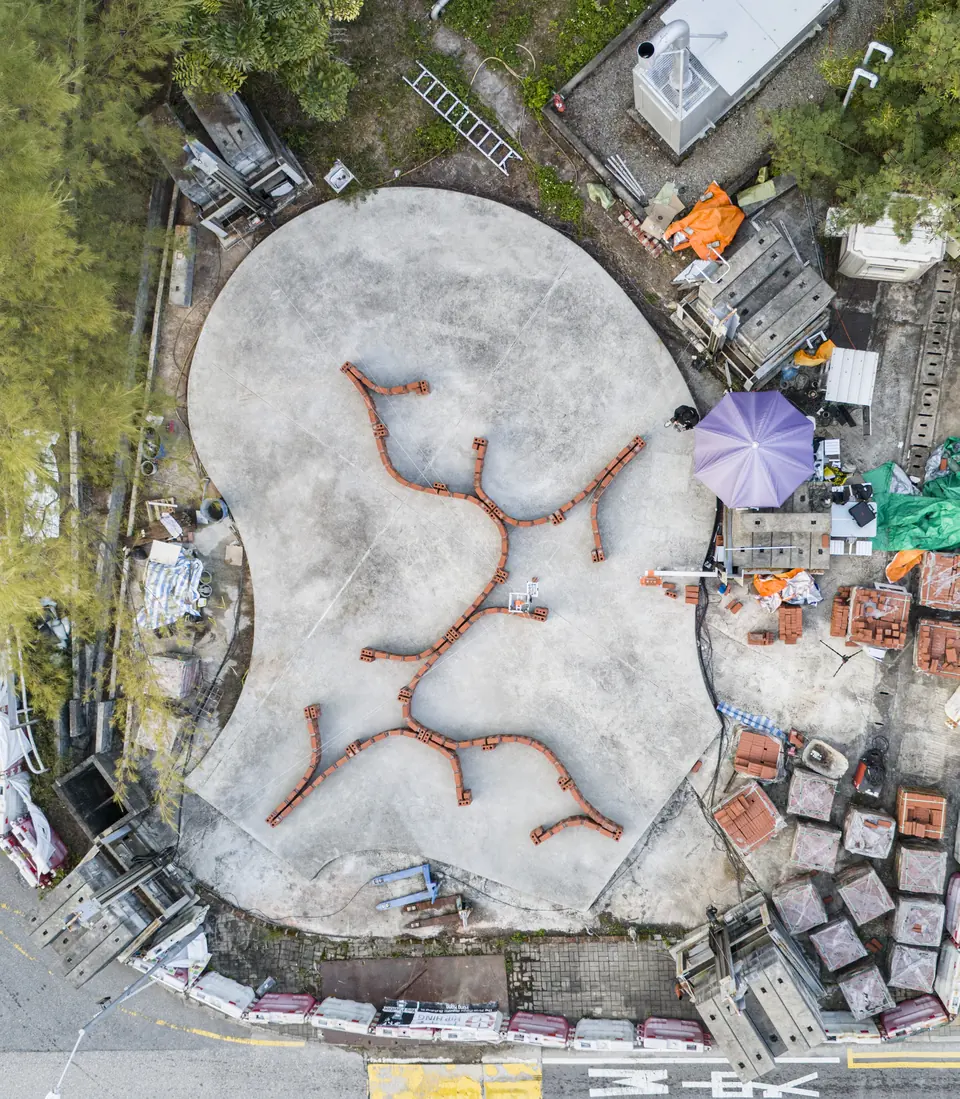
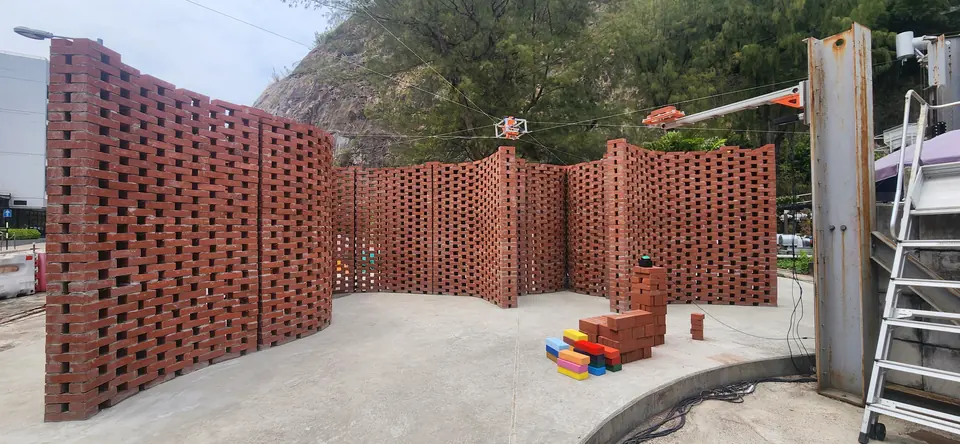
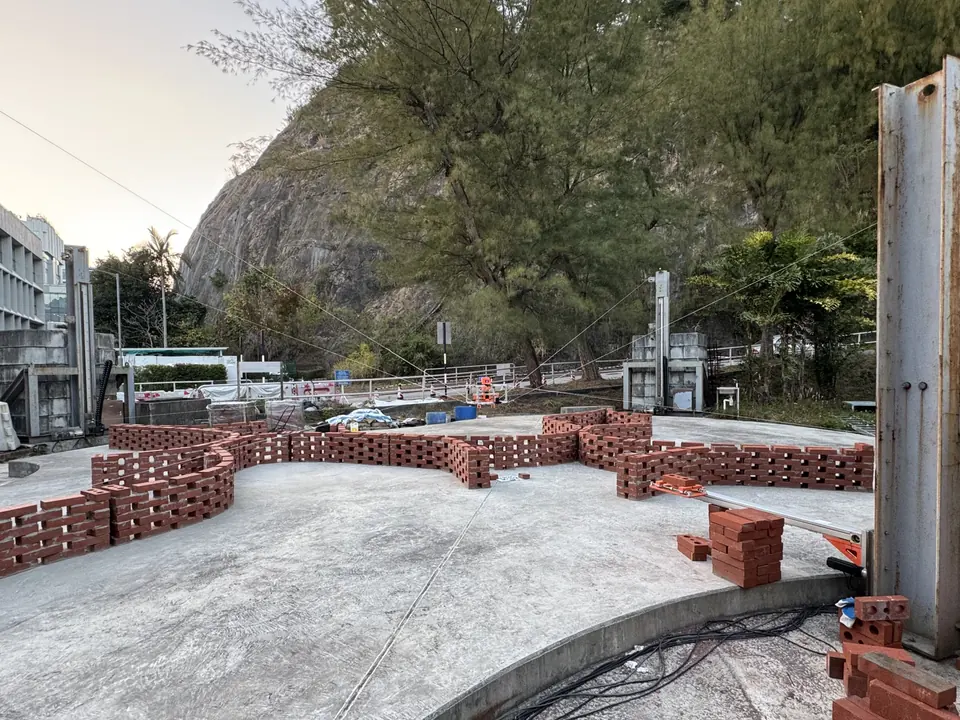
CU-Brick is a cable-driven parallel robot for automated brick placement. At the Yard for Environmental Sustainability (YES) Pavilion, it positioned bricks across a large construction workspace while workers applied mortar and checked the brickwork.
Inside CU-Brick
Explore the cable-driven robot, then look inside its brick-handling end effector.
Pick from conveyor
Play the cycle or drag the timeline to follow one brick from conveyor to wall.
Components
- Pole 0 · motors 0, 4
- Pole 1 · motors 1, 5
- Pole 2 · motors 2, 6
- Pole 3 · motors 3, 7
- Motorized winches × 8
- Adjustable lower pulleys × 4
- Positioning cables × 8
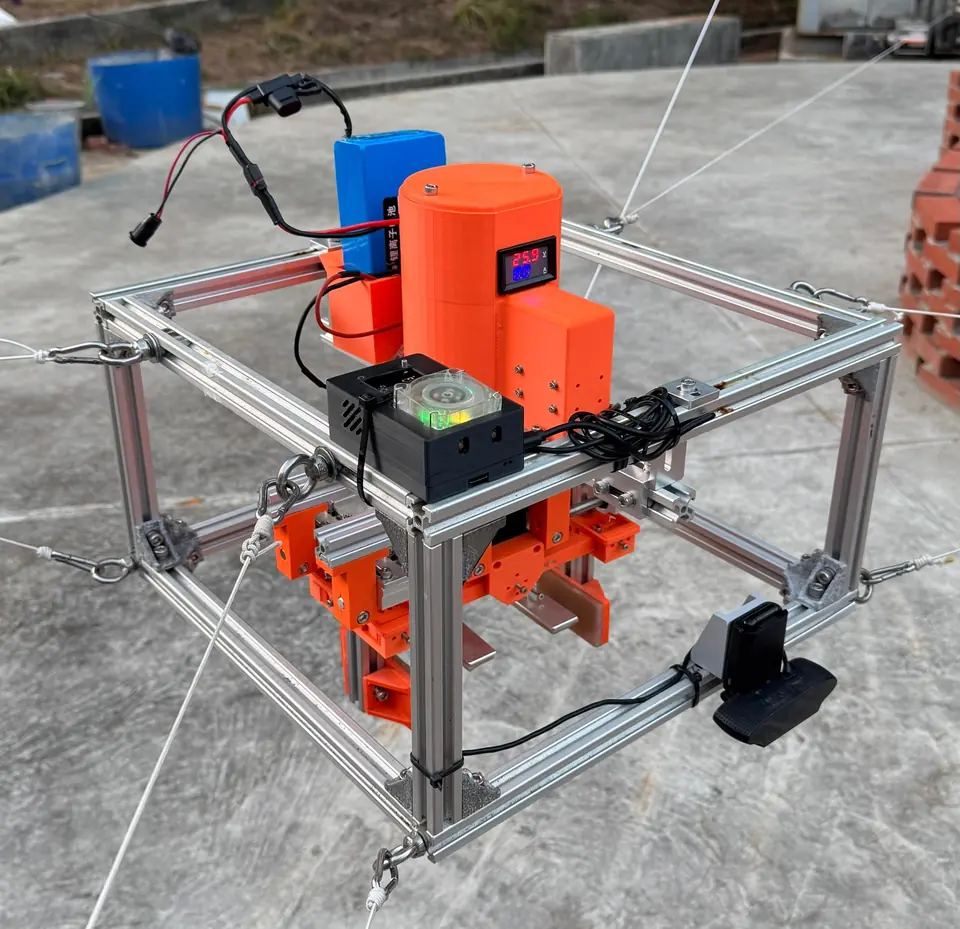
- Suspended end effector
- Brick pick-up pole
- TX2-60 transfer arm
- Brick feed conveyor
Turn the held brick, then slide to release. Reverse to grip again.
Raise the four lower pulleys to clear the growing brickwork.
The 3D view is unavailable. CU-Brick uses eight motorized cables on four poles to position a wireless gripper. Four lower pulleys rise as the wall grows; a separate pick-up pole presents bricks to the robot. The project photos above show the assembled system.
Simplified site layout; arm reach and end effector enlarged for clarity. The cycle illustrates brick transfer and placement with moving cables. End-effector controls show rotation, gripping and release; separation groups hardware by function.
Project Details
The YES Pavilion project used more than 5,800 bricks across 40 layers, reaching 2.5 m in height within a 13 m by 9 m work area.
Fiducial-marker localization and 3D scanning support calibration. An elevation system raises the lower cable attachment points as construction progresses, helping the cables clear the growing brick structure.
CUHK Engineering: the construction workflow and deployment
TVB News: CU-Brick media coverage
Now News: CU-Brick media coverage
i-CABLE News: CU-Brick media coverage
RTHK News: CU-Brick media coverage
Awards & Recognition
- CU-Brick: Second Runner-up, Open Section, YPEC 2025
- CU-Brick: Merit Award, Open Category, OSH Innovation and Technology Award 2026
Publication & Project Updates
- Peer-reviewed CU-Brick paper presented at CableCon 2025
- CableCon 2025 presentation update
- YPEC 2025 exhibition update
Selected Contributions
- Designed and implemented the cable-driven robot for a full-scale construction project.
- Supported robotic brick placement for the 2.5 m-high, 40-layer structure, working alongside the contractor's mortar application and quality checks.
- Integrated fiducial markers and high-resolution 3D spatial data for calibration and localization.
- Designed and manufactured the robot's electrical and control boxes.
- Co-authored and presented the CU-Brick paper at CableCon 2025.
- Supported public demonstrations and coverage by TVB News, Now News, i-CABLE News, and RTHK.
- Helped prepare the project for YPEC 2025, where it was named second runner-up in the Open Section, and for the 2026 OSH Innovation and Technology Award, where it received an Open Category Merit Award.