Robotics in practice
I'm Leo Cheung, a robotics engineer based in Hong Kong. I work on construction robots, humanoid systems, and human-robot control interfaces.
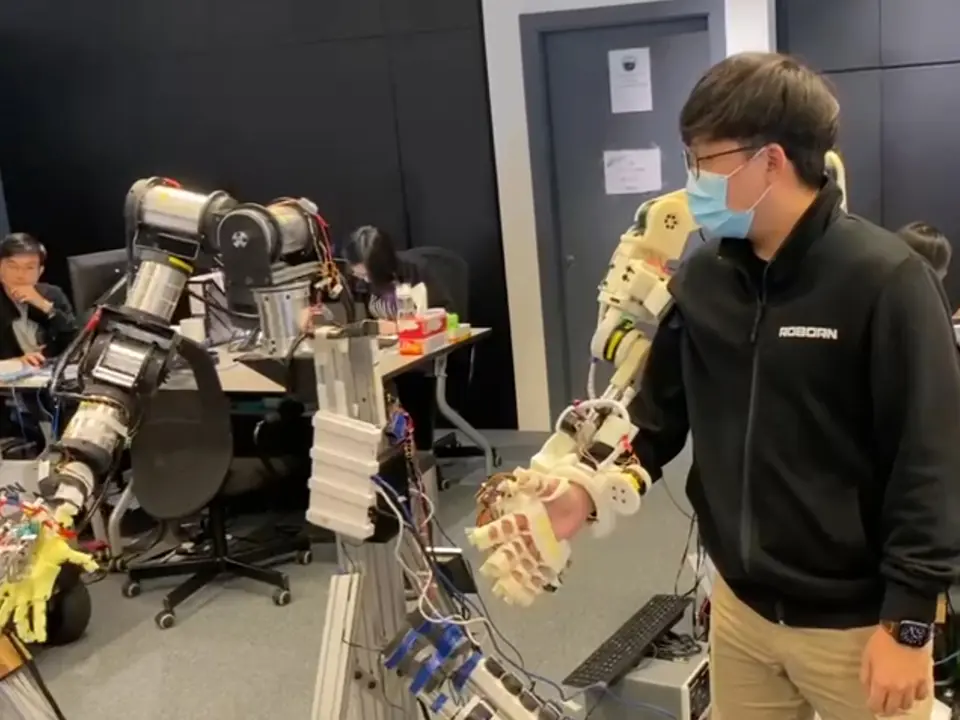
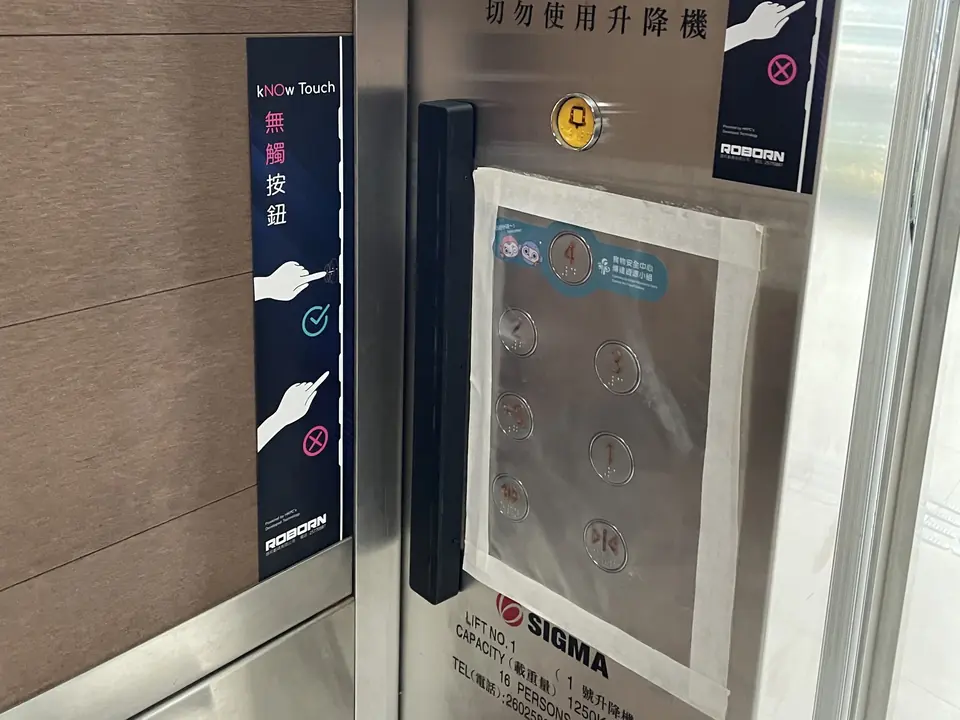
My work spans mechanical design, electronics, ROS software, and field testing. Projects include CU-Brick, RoBosun-Tapper, ME4, and the SuperLimb foot controller.
Explore the robots
Pause over a photo or tap to explore in 3D.
-

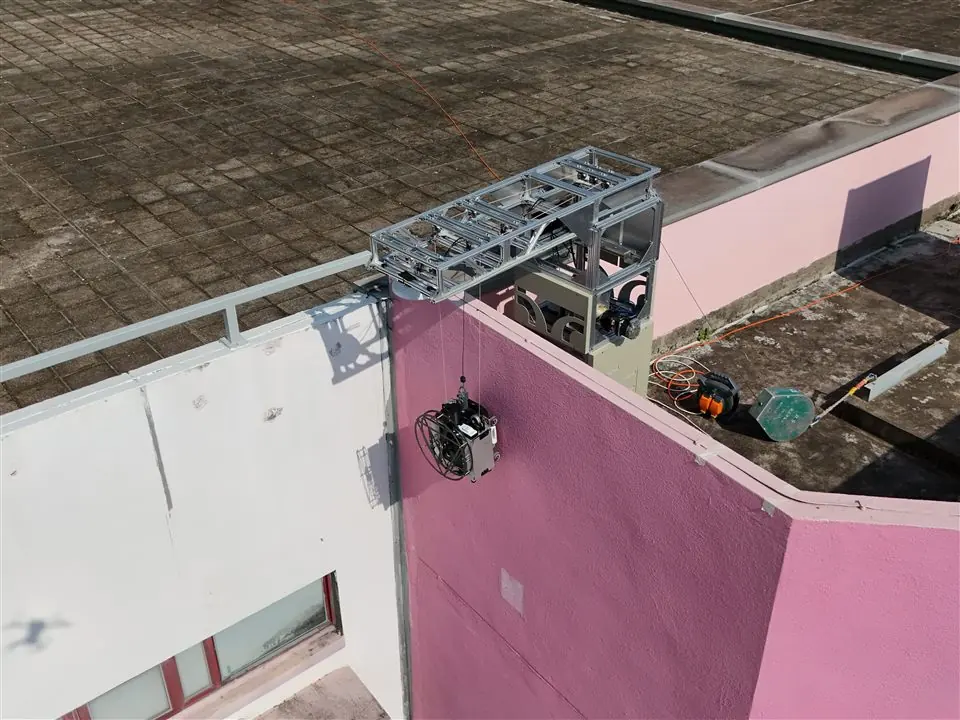
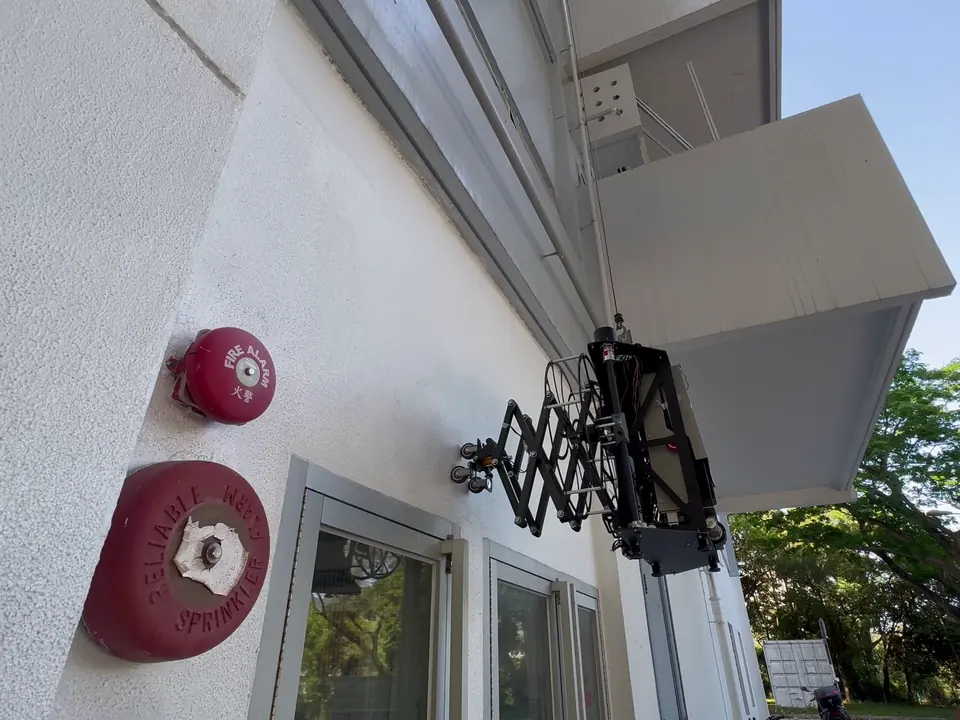
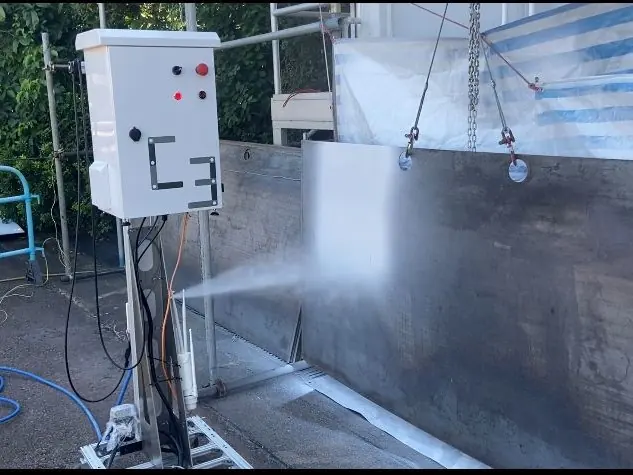
RoBosun-Tapper
Cable-driven facade hammer-testing robot
Pause the cursor over the photo, or activate the View 3D model button. Drag horizontally or use the left and right arrow keys to rotate. Use + and − to zoom; Home resets the view. Escape returns to the photo.
-
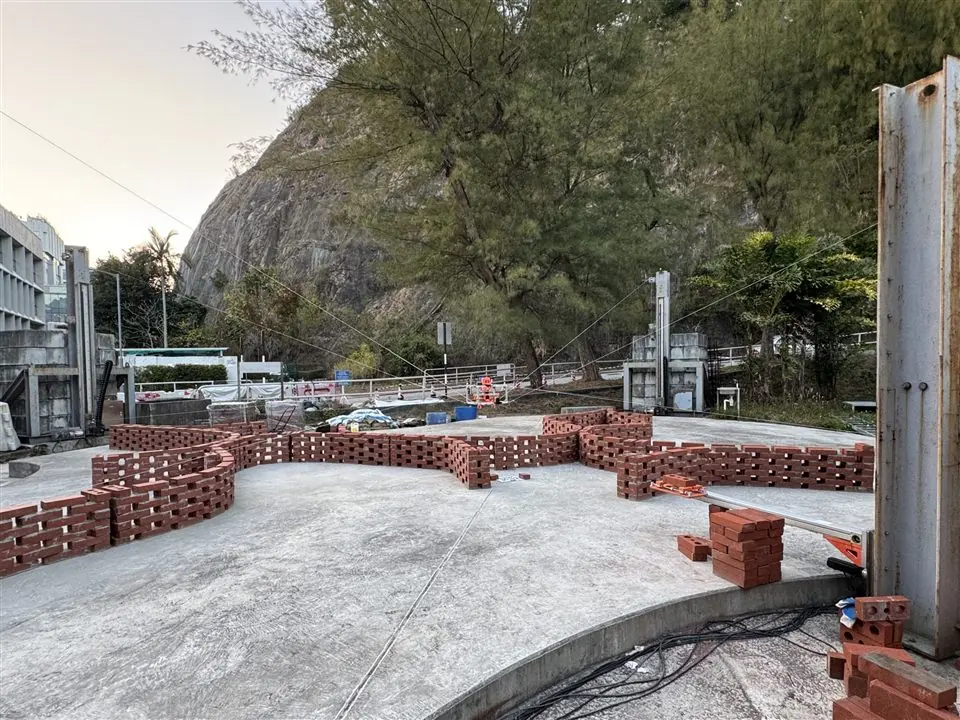
CU-Brick
Cable-driven bricklaying robot
Pause the cursor over the photo, or activate the View 3D model button. Drag horizontally or use the left and right arrow keys to rotate. Use + and − to zoom; Home resets the view. Escape returns to the photo.
Selected work
What I do
-

Software development
Develop ROS-based software for robot control, navigation, signal processing, motor control, operator interfaces, and wireless communication.
-

Hardware design
Design robot mechanisms and electrical systems, and build prototypes using CAD, 3D printing, CNC machining, sensors, and embedded electronics.
-

Project management
Coordinate project requirements, suppliers, system integration, field testing, schedules, and safety documentation.
-

Research & publications
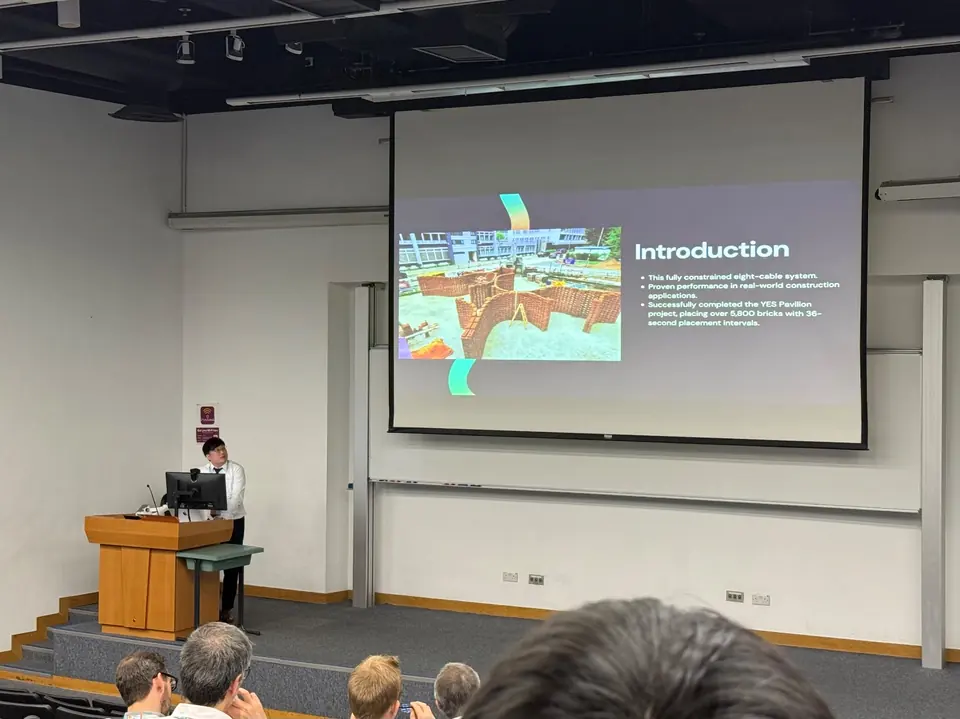
Document experimental results and share engineering findings through technical reports, peer-reviewed publications, and conference presentations.